
The picks that still go to people.
Soft goods, poly bags, cords and kits are where picking robots struggle most: clear film glares, two bags are picked as one, pouches slip and foam gets crushed.
Tasks
Where pick-and-place breaks, and what touch fixes.
1D
Cords and cables in kits
- Why it breaks
- Loose cords tangle, snag and change shape mid-pick.
- If missed
- A missing or tangled item, a rejected kit.
2D
Opening, filling and sealing poly bags
- Why it breaks
- Clear film glares; two bags stick together.
- If missed
- Two bags picked as one, or a torn bag.
3D
Soft goods into totes, without damage
- Why it breaks
- Light and crushed look the same to a camera.
- If missed
- Crushed product, a rejected kit.
3D
Holding soft pouches without dropping them
- Why it breaks
- Slip is visible only once the pouch falls.
- If missed
- Dropped items, a stopped cell.
Proof
Tote-to-tote, from an instruction.
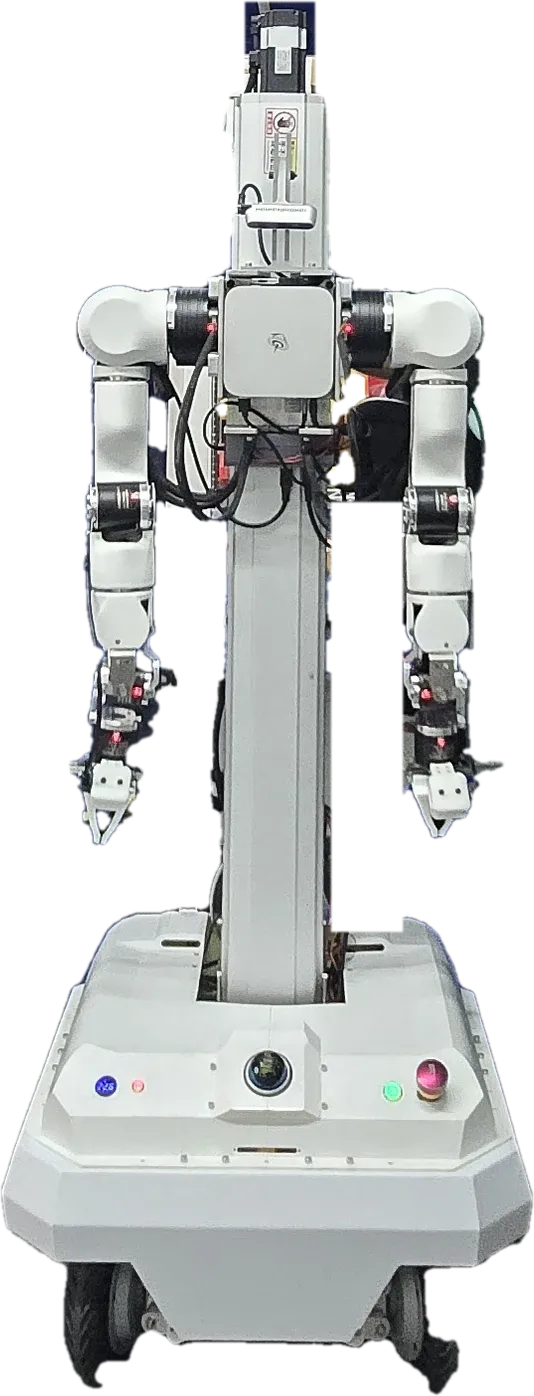
AdiBot has demonstrated tote-to-tote picking with Auto-Executor: an instruction becomes tasks, tasks map to skills, and missing skills are learned in simulation. Below: how it works, and the robot doing it.
Auto-Executor · tote-to-tote picking
Illustrative schematic
01 · Instruction
“Move the three items from tote A to tote B.”
02 · Tasks
- 1Find item 1 in tote A
- 2Pick it
- 3Place it in tote B
- 4Repeat for items 2 and 3
03 · Skills
- locateknown
- graspknown
- placeknown
- re-grasp a tipped itemlearned in simulation
AdiBot v1.0 · 2× speed
Skill · Rigid
Tote-to-tote picking from an instruction
Simulation · illustrative
Skill · 1D
Seating a connector, vision-only vs touch-aware
Physics simulation with scripted control, not hardware. Same 2 mm depth error from vision; only the touch-aware run confirms the latch.
Video coming soon
Skill · 3D
Grasping soft goods
Video coming soon.
Video coming soon
Skill · Rigid
Picking mixed items for a kit
Video coming soon.
The model
Robots that work like staff.
Add or remove capacity without a capital project or an integration project.
Path
- 01Warehouse kitting
- 02Cable and connector work
- 03Wire-harness assembly